Showing posts with label Sourcecode. Show all posts

Thursday, July 3, 2014

Fiducial Mark Detector

A fundamental problem in photogrammetry is to determine the camera parameters. These camera parameters can be categorized into (1) interior orientation parameters, and (2) exterior orientation parameters. In this blog, I present an application to determine the interior orientation parameters.

The main interior orientation parameters (IO) or intrinsic camera parameters are (1) focal length and (2) principle point coordinates. The program I am presenting here is to find the fiducial marks in which we can further reveal the principle point positions.

For the implementation, the cross correlation coefficient is employed to search for the fiducial marks. This can be said as a template matching problem. The application screens are shown below:

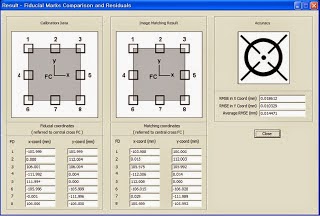

The program is developed using the C/C++ language using MS Visual Studio .NET 2003. I have not used any library. The image processing is done in pixel-wise using the class CImage that comes with MFC.

This program is part of my assignment for the Digital Photogrammetry subject (2010, Summer).

[Sourcecode][Executable][Assignment Report]

The source code is now available on Github: https://github.com/stanathong/fiducial_mark_detector.

LiDAR Viewer in 2D Raster Format

The LiDAR Viewer project is part of my assignment for LiDAR class (2009 Winter).

The application reads XYZ or XYZC file (in which X,Y,Z is 3D coordinates and C is color) and visualize the results in the form of 2.5D image. It offers zoom and pan functionality.

The program was developed using MS Visual Studio .NET 2003 using the CImage class for presenting image.

The application screen is presented below.


[Sourcecode][Executable][Testdata,7MB]

The source code is now available on Github: https://github.com/stanathong/lidar_viewer.